Day 10: my first robot — it just doesn't talk yet
It’s been quiet here for a while. Vacation season — let’s leave it at that and skip the boring account of everyday life getting in the way.
Turns out quiet didn’t mean stalled. Every AliExpress order landed at once. The Gemini camera showed up — genuinely good-looking hardware, the first thing in this build that looks like it belongs on a robot instead of in a shopping cart. The Jetson also arrived. Technically. Not to me — to some intermediate stop of its own I still haven’t told you about. That story isn’t over. I just keep finding new ways to not get to it.
With actual parts on the desk instead of a wishlist, I stopped designing for a minute and started printing. First up was the mounting platform from a few weeks back — the one I signed off on-screen while admitting, and I’m quoting myself here, that it was “a very confident render” whose real-world fit was a separate question for a separate day. Today was that day. A few rounds of dimension-chasing later, it exists: the sliding grooves work, the little interposer blocks slide and lock down where they’re told to.
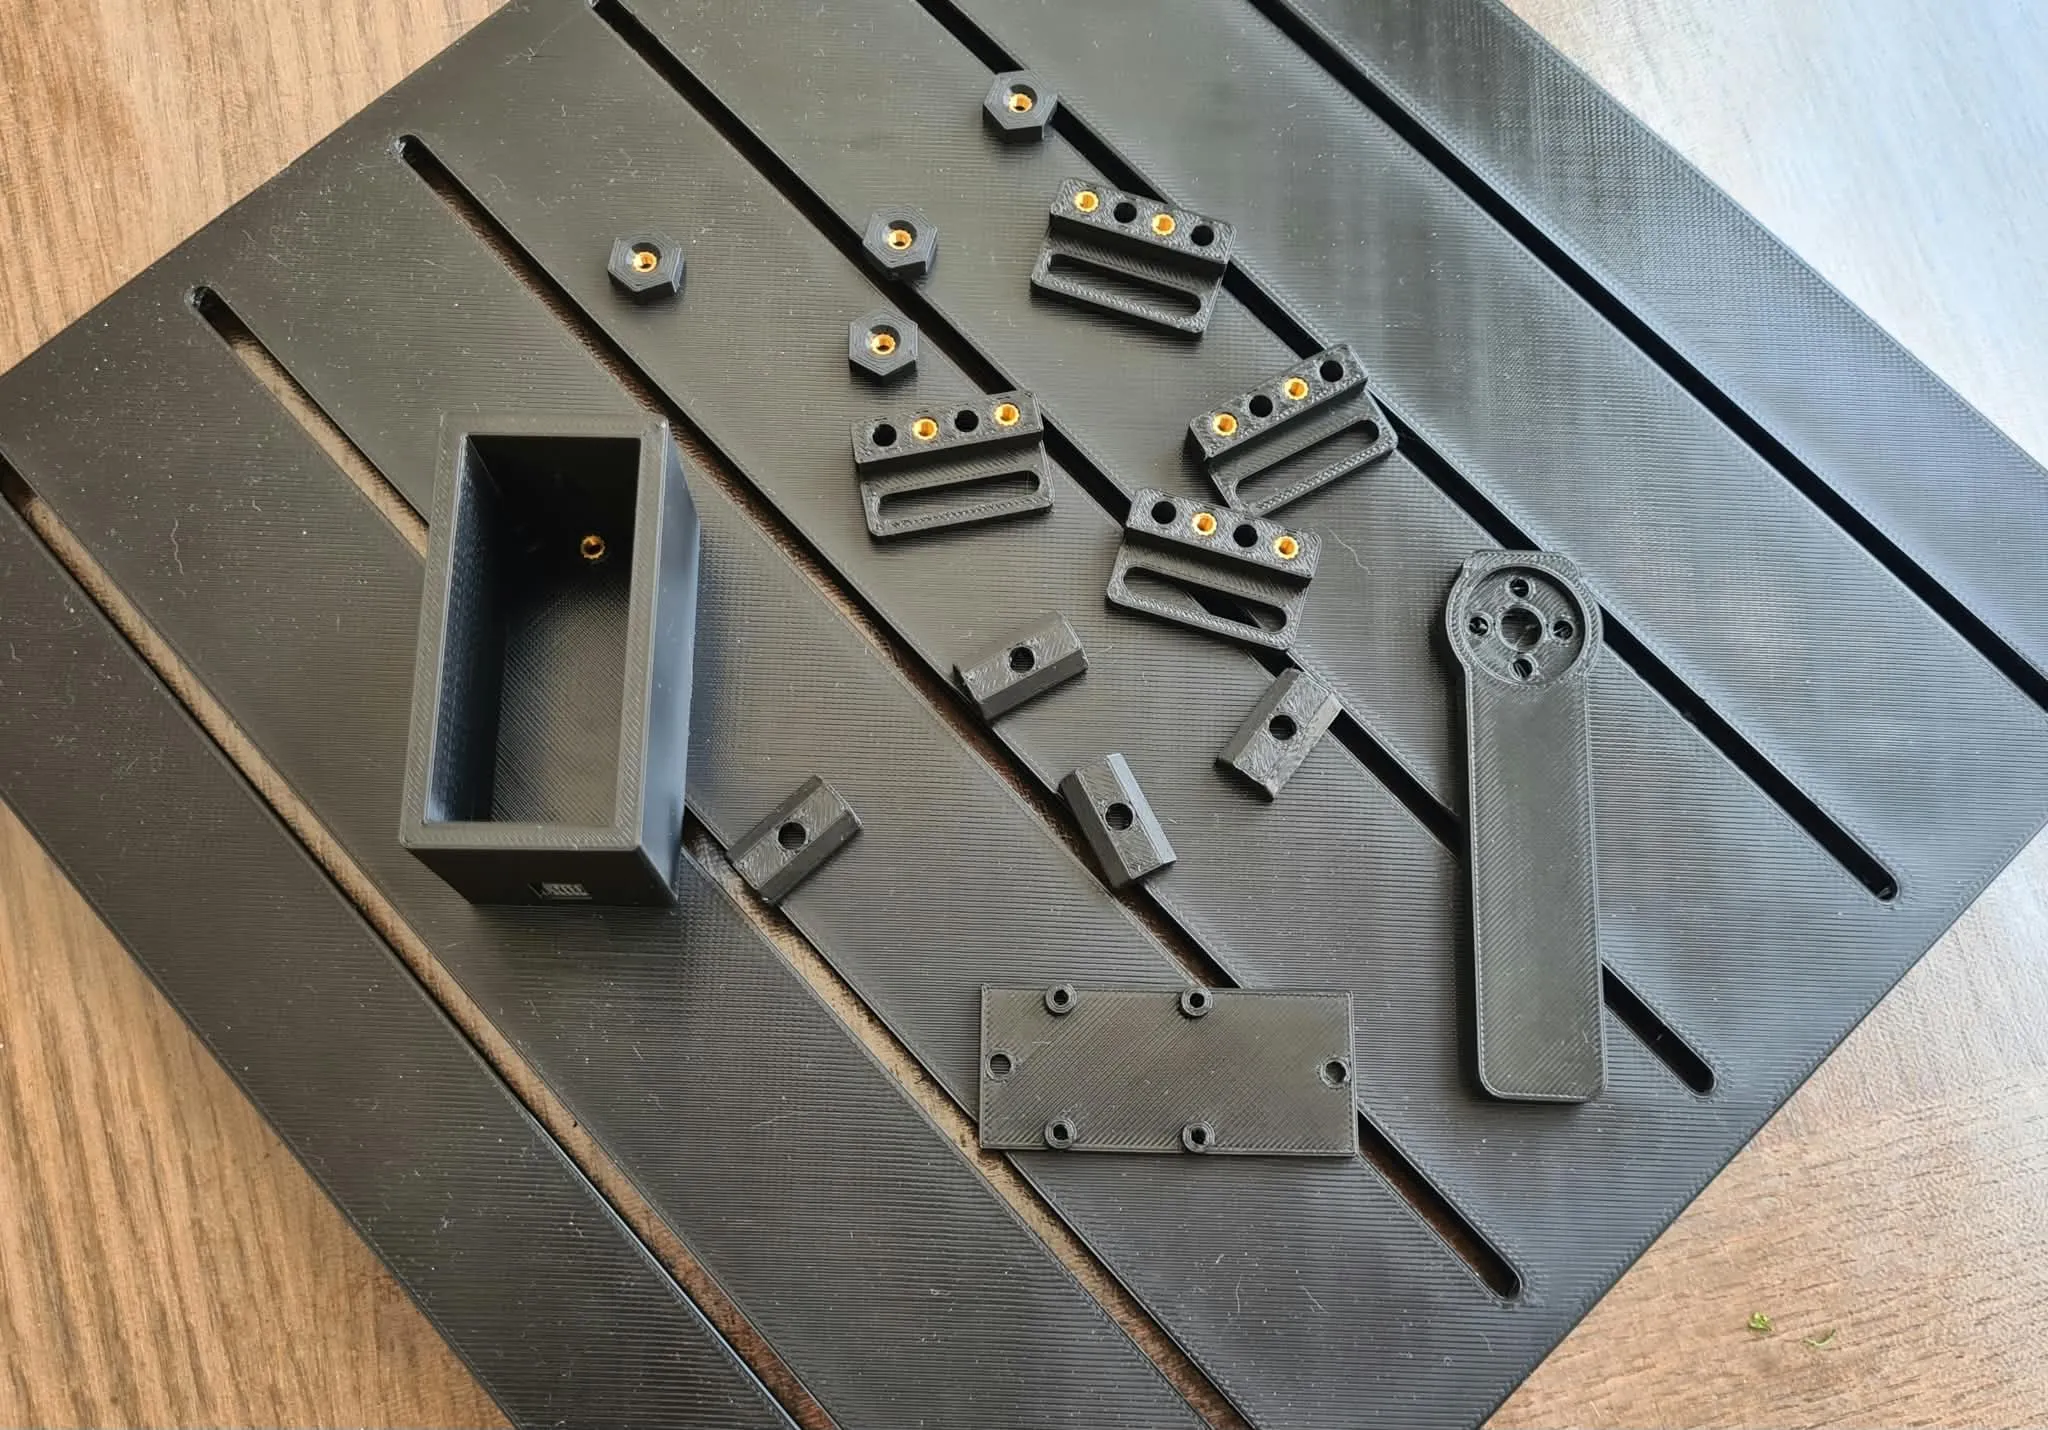 Everything on this table used to be numbers on an order form.
While the first joint bracket was printing, I finally got to do something I’d been looking forward to since the heat-set inserts arrived: press one into plastic for real. It’s a genuinely satisfying two seconds — soldering iron down, gentle push, and an empty hole turns into a proper threaded socket, like the part just grew metal exactly where it needed it. I ran out of holes to practice on faster than expected. A good problem, as these things go.
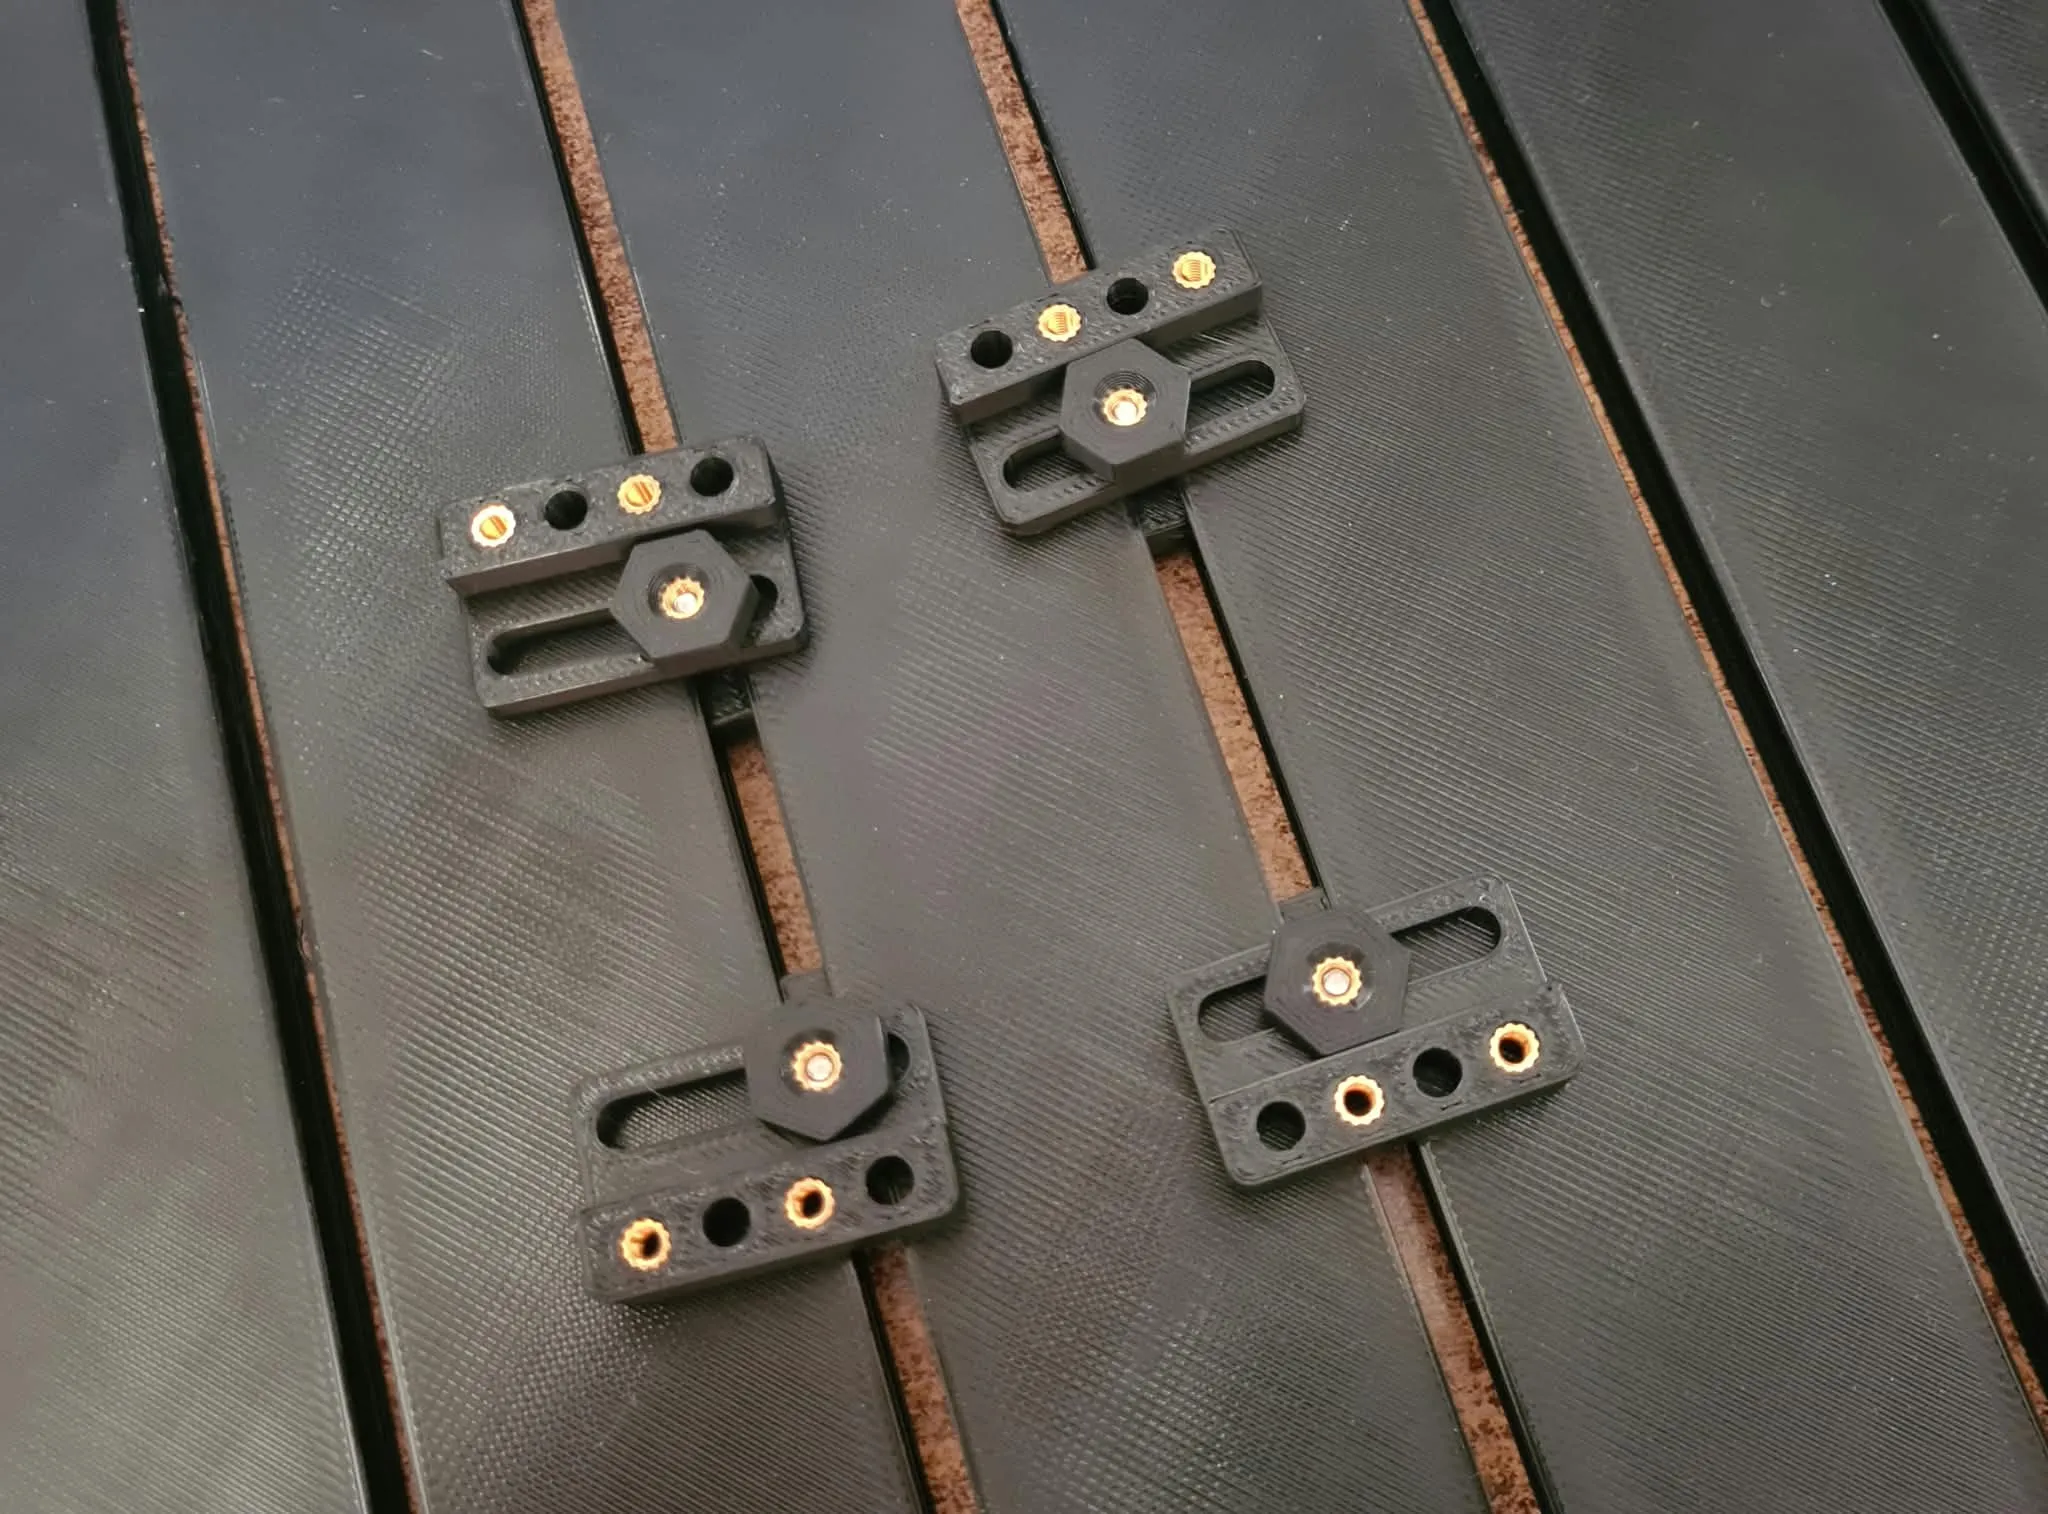 The most satisfying two seconds of the whole build so far.
Then the bracket finished printing, and assembly went about as smoothly as everything else in this project so far — which is to say, not remotely. Three separate problems, discovered in the worst possible order. The mounting-hole spacing was off. The servo wouldn’t sit flat against its own plate because of a small raised nub on the back — the one thing I’d apparently measured everything except. And the bracket’s own base holes turned out to be close enough to its walls that the screw heads had nowhere to go; the walls themselves were in the way. Four attempts. On the fourth, it went together.
Once the thing was actually screwed together, I went back into the source files instead of just filing the win and moving on — nudged the base holes further from the walls so the screws have somewhere to land, and cut a clearance hole into the mounting plate for that back-of-servo nub that kept fighting me. Neither fix changes what’s sitting on my desk right now. But the next one off the printer should go together in one attempt instead of four.
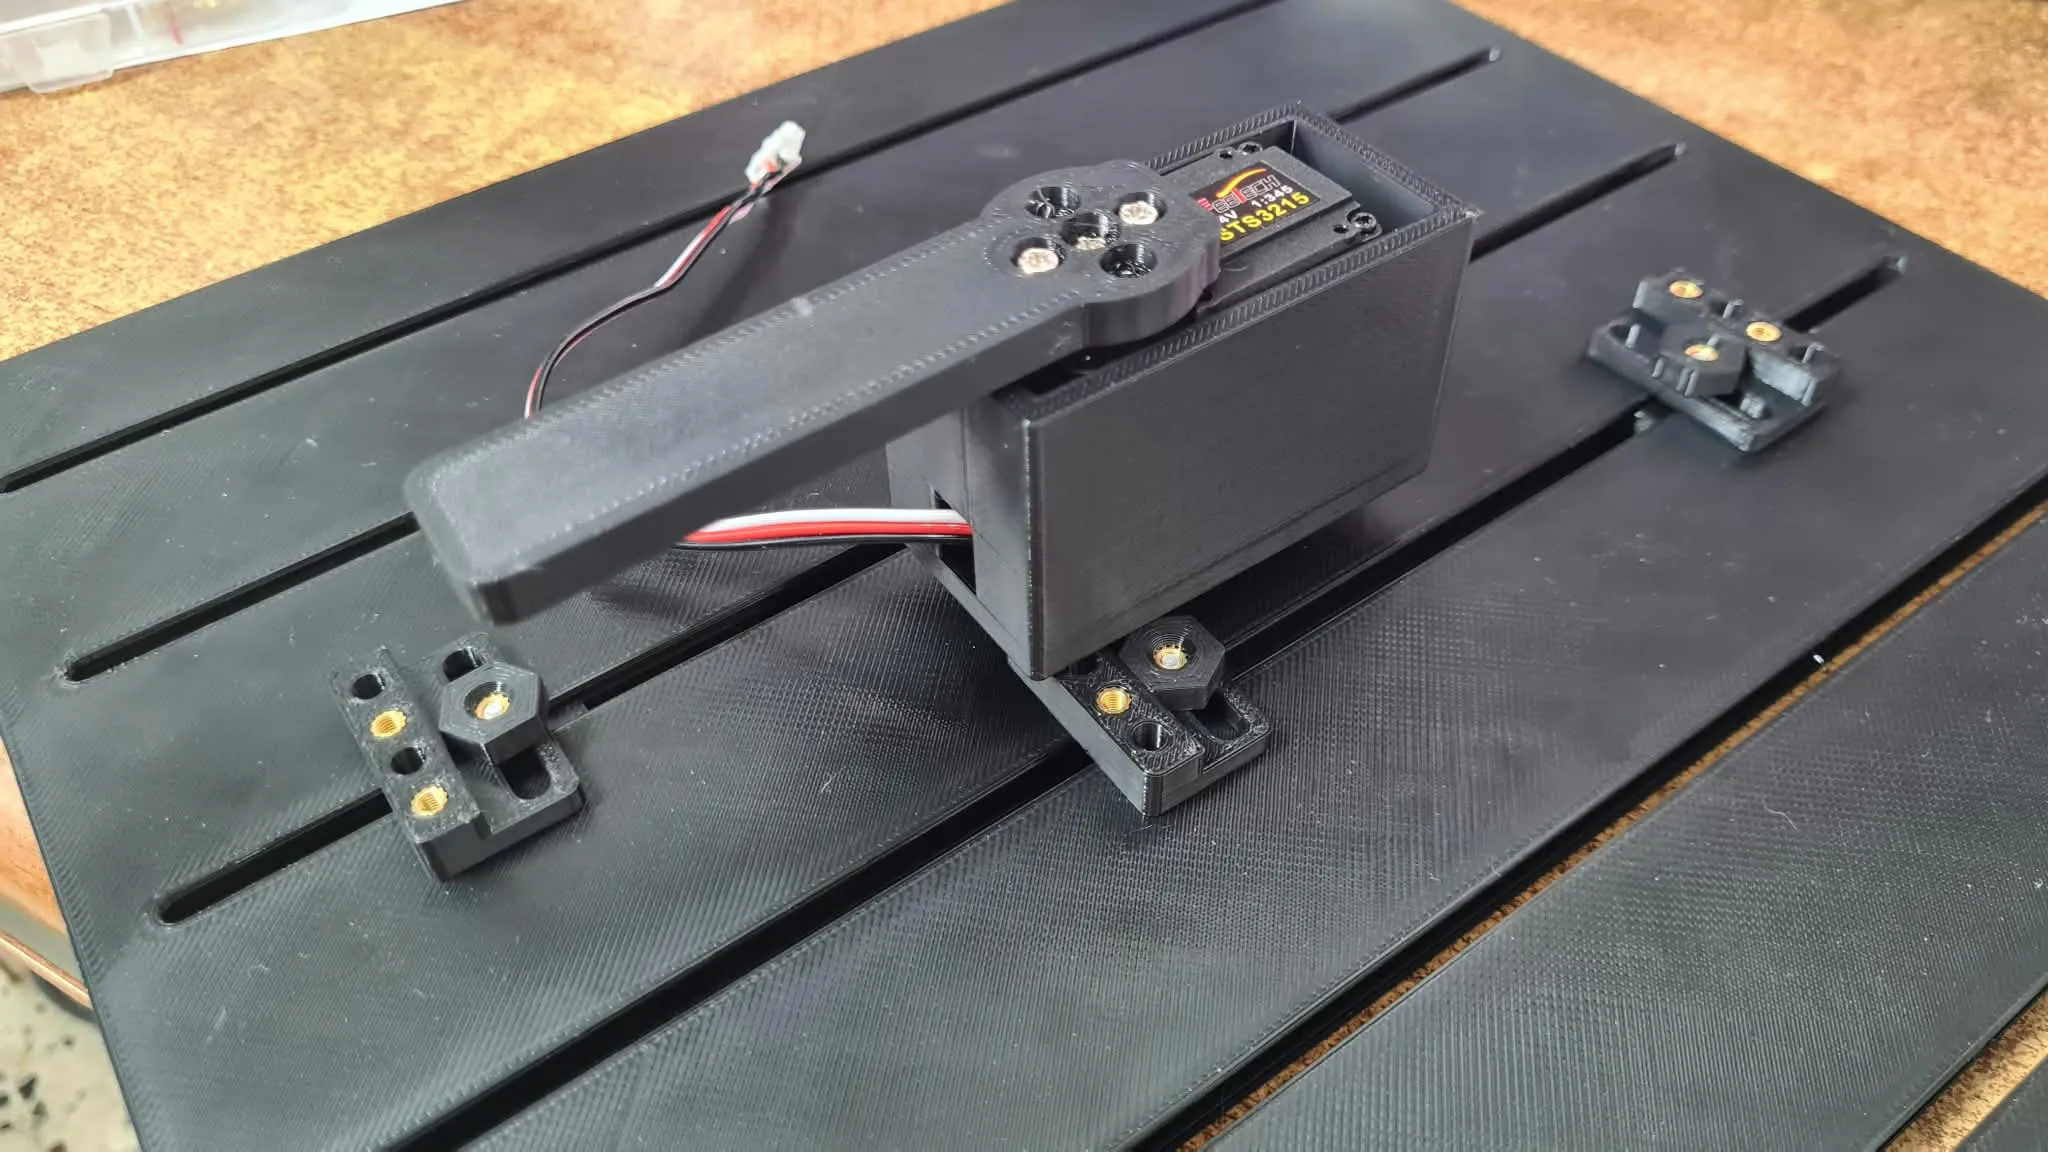 My first robot. It just doesn’t talk yet.
Here’s what four attempts and a stubborn afternoon bought me: a servo, a bracket, and a mounting plate that finally agree with each other. Not much yet — one joint, no brain, no idea if it’ll ever hold a conversation. But it’s mine, it’s real, and it’s the first thing in this whole build that isn’t a render, a spec sheet, or a number on an invoice. Can’t wait to see if it actually thinks, once the brain shows up.