Day 5: something I can finally touch
I’m tired of building castles in the air that go nowhere. I want something real — I WANT A RESULT. Here. Now. Something I can touch, check, actually watch happen.
So today we reworked Day 1’s bracket for the new servo, and got exactly that. Here it is:
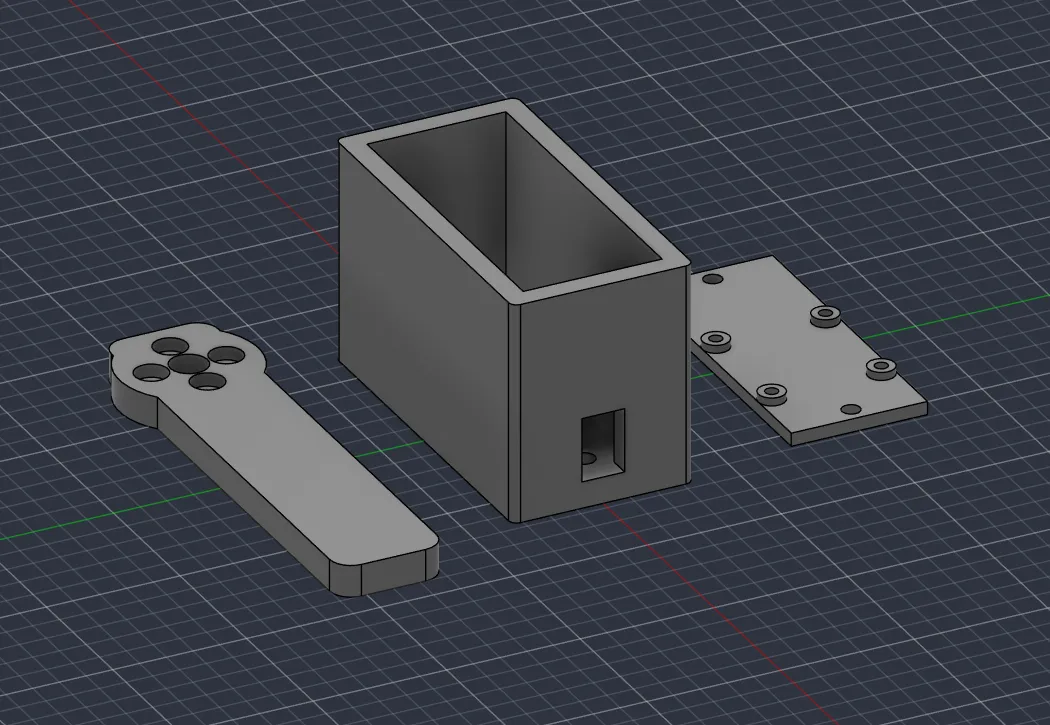 Day 1’s design, rebuilt around a motor it was never originally cut for.
Riding that burst of actually-making-something energy, we went back to planning and worked through what switching servo families really costs. Feetech builds a full toolset for its own components to talk to each other — and none of it talks to anyone else’s. That has two consequences. First: every servo on this robot now has to come from the Feetech family, at least for this joint (we were already leaning that way; this just made it official). Second: the PCA9685 board — day one’s entire reason for existing — doesn’t work on this bus at all. It’s a Feetech FE-URT-2 instead. Small mercy: the whole parts list turned up on AliExpress at prices that didn’t make me flinch.
We also decided against buying a mounting bracket for the servo. We have a 3D printer sitting right there — this is exactly the kind of small part a home lab should be printing and fitting to its own needs, not ordering off a shelf. (It’s the plate on the right in the picture, next to the servo housing.)
Another genuinely productive day.
Oh, and — almost forgot — I also ordered a set of brass heat-set inserts, matching bolts, and a soldering-iron tip to actually set them into the printed parts. All together: about $40. After the numbers this project has been throwing around lately, that felt like finding change in a coat pocket.